DOC 01GETTING STARTED
The application
LEVIATHAN is one desktop application with six workspaces, laid out in the order of the engineering work: CAD Studio to design parts, Hardware to wire the electronics, Code to write and run the software, World to simulate, Dashboard to analyse, and Hull for naval architecture and hull operations. Alt+1 to Alt+6 switch between them from anywhere, and LEVIATHAN opens on the World. All six share one local simulation service and one project.
| Workspace | Use it to | Guide |
|---|---|---|
| CAD Studio Alt+1 | Sketch and model parts, give them a material, measure them, export them, and send them to the World as solid objects | CAD Studio |
| Code Alt+3 | Create robotics projects from templates, edit and test them, and run controllers closed-loop against the simulation after approving the exact command | Code |
| Hardware Alt+2 | Wire a harness, check it against wiring and power rules, generate firmware, and run firmware against simulated sensors | Hardware |
| World Alt+4 | Fly a vehicle in one of nine scenes with its sensors and overlays, in up to four views | World |
| Hull Alt+6 | Lines, offsets, hydrostatics and intact stability; fouling, fuel cost and hull-robot cleaning plans | Hull |
| Dashboard Alt+5 | Plot and measure runs on a shared timeline, and open the 85 analysis tools | Dashboard |
The shell
Every workspace sits in the same frame. Across the top: the menus File, Edit, View, Insert, Tools, Simulate, Window and Help, the search box and the account control. Below them, the workspace tabs. The window title shows the open project, with a • while a document is unsaved.
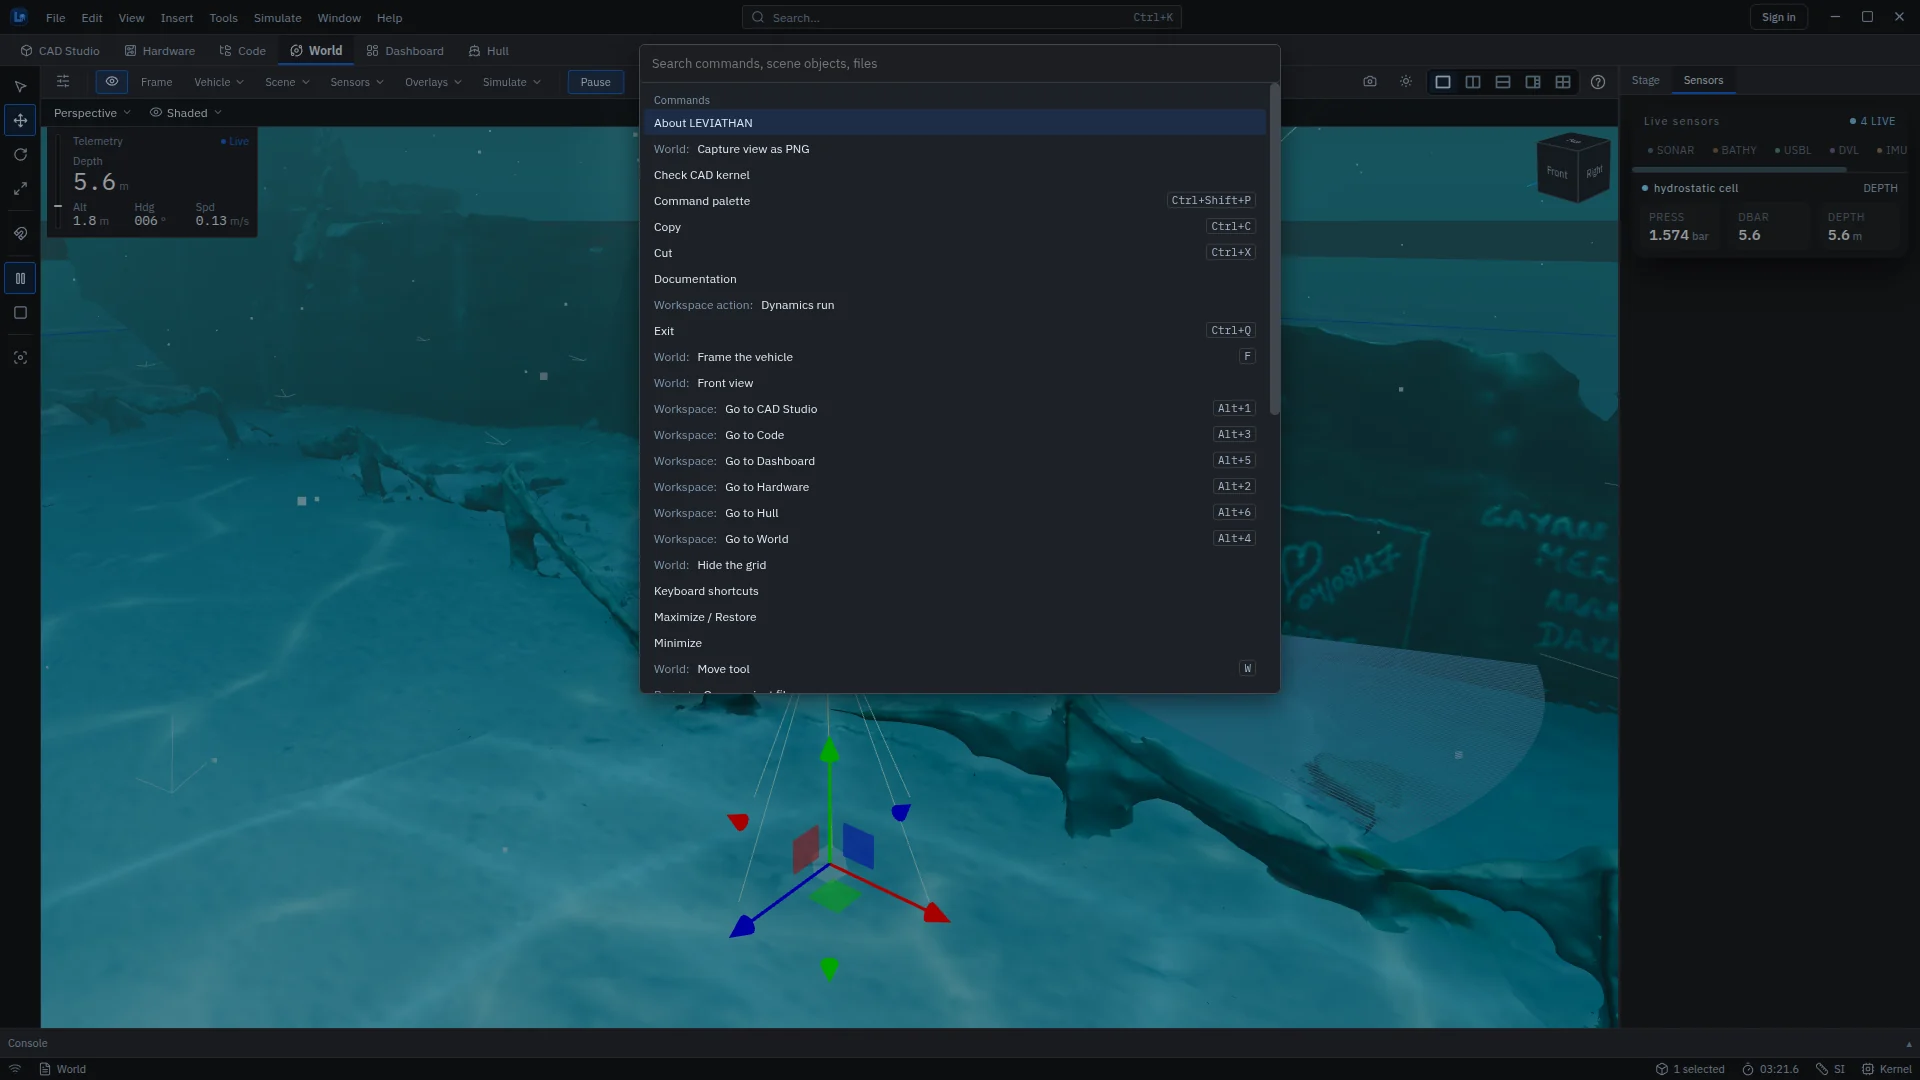
- Menus show only what applies to the current workspace. A command that cannot run is greyed out, and its tooltip says why.
- Search and commands. Ctrl+K (or Ctrl+Shift+P, F1) opens the palette. It finds commands, objects in the World and features in CAD Studio, and files in the open project.
- Status bar. The connection to the simulation service (with Reconnect when it is offline), the workspace and project, unsaved documents, the cursor position in orthographic views, the number of selected objects, simulation time, units (SI) and the state of the CAD kernel.
- Console. The strip above the status bar opens Output, Terminal, Problems and Debug Console.
- View ▸ Show Performance Stats adds frame-rate figures to 3D views. Window ▸ Reset panel layout restores the default layout. Help ▸ About LEVIATHAN shows the version.
- Undo belongs to each workspace: the World keeps 100 steps, Hardware 60, Hull offsets 50, CAD Studio's history is kept by the service, and Code by the editor.
CAD Studio
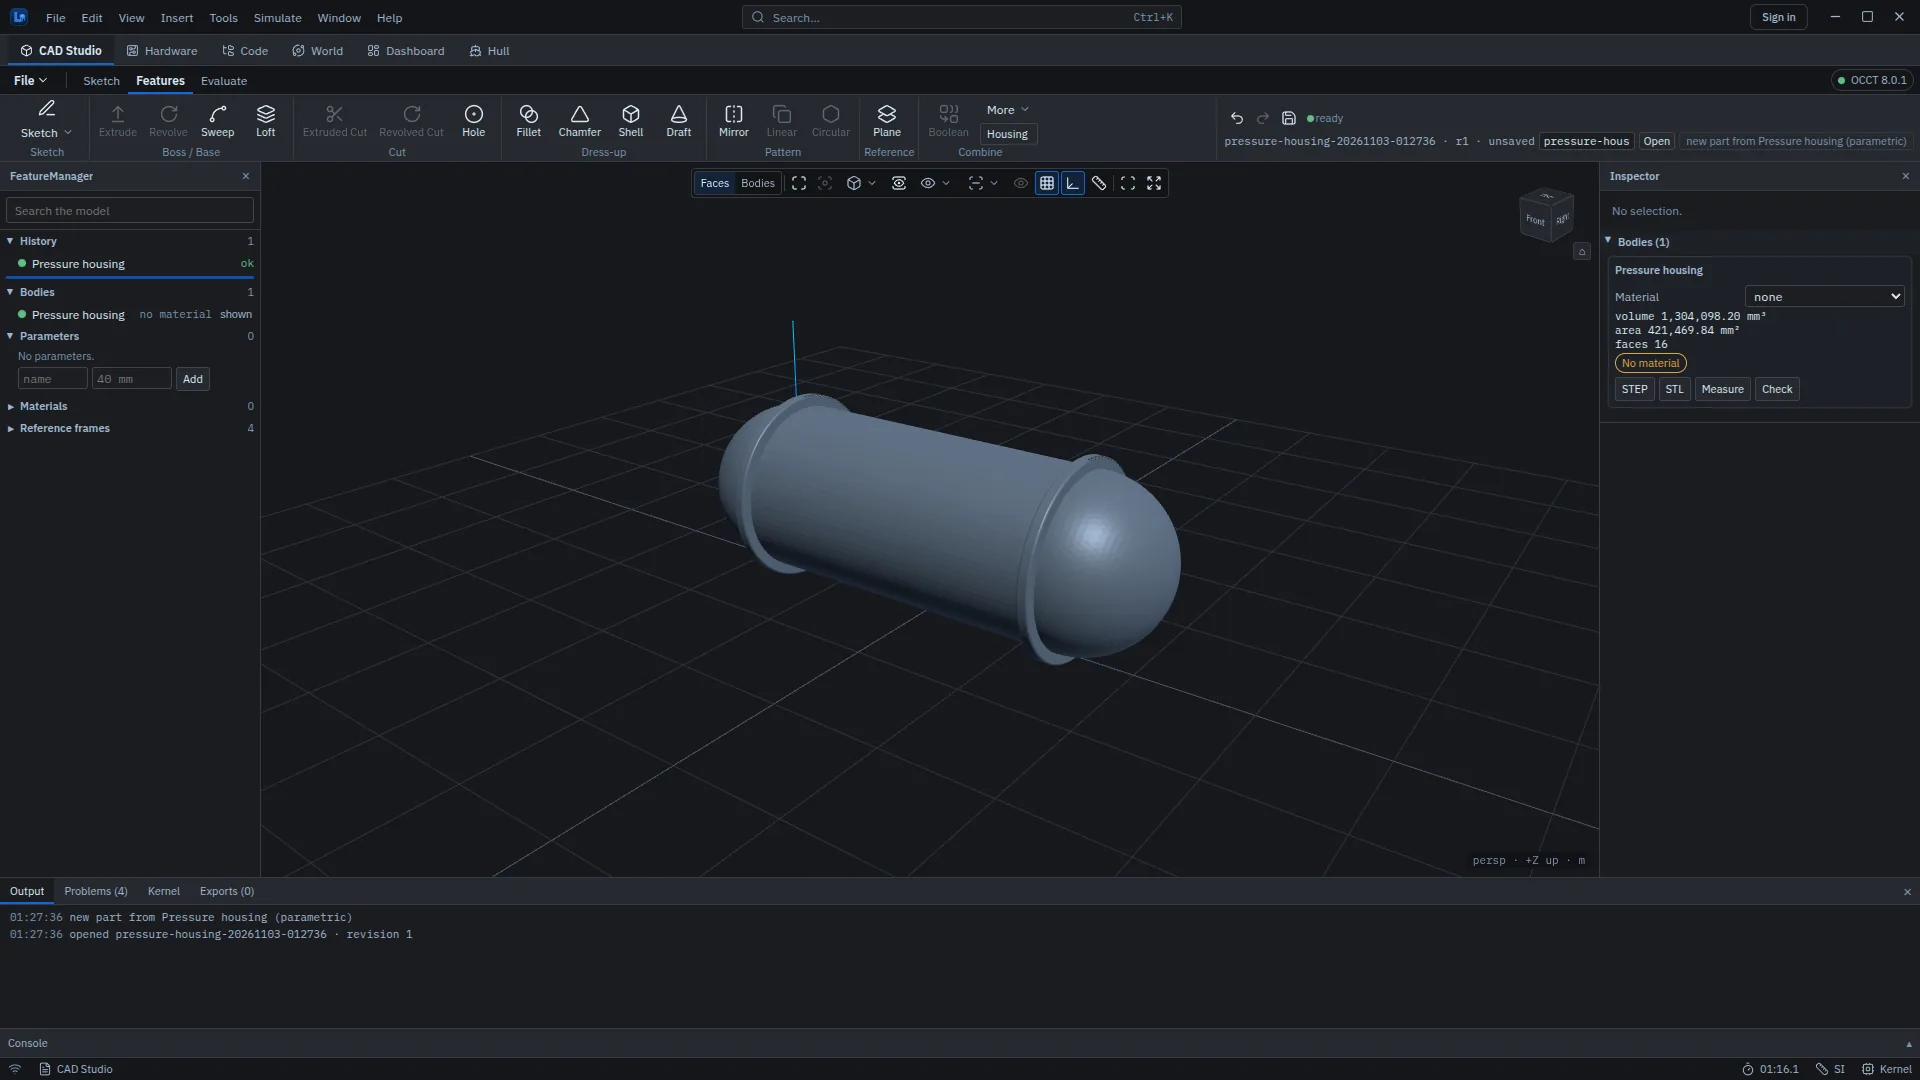
A parametric part modeller for the parts a marine robot needs: pressure housings, flanges, end caps, brackets and hulls. Sketch with dimensions and relations, build features with a live preview, measure, assign a material, read mass properties, and export STEP, STL or GLB, each export re-read and verified.
Code
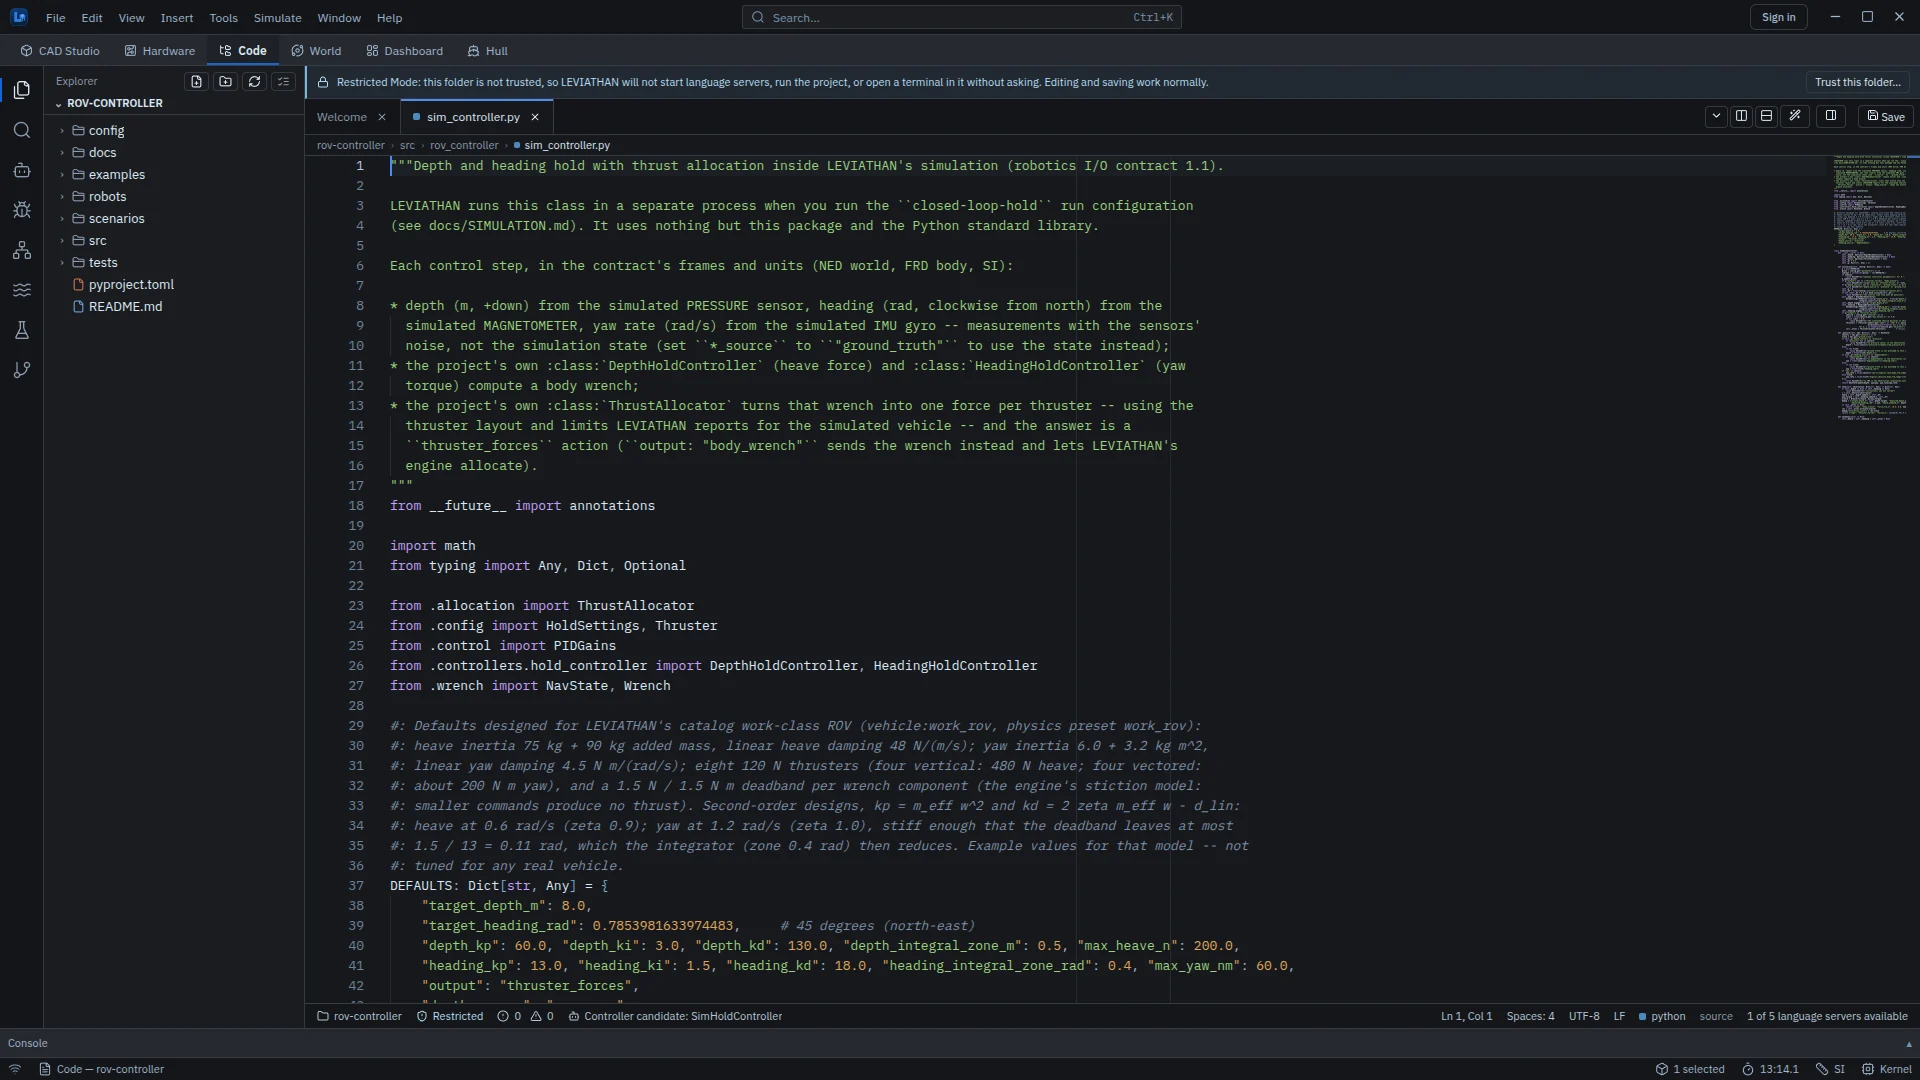
A full editor for robotics software, with twelve project templates, Restricted Mode for untrusted folders, run configurations that run only after you approve the exact command, controller simulations against LEVIATHAN's physics, terminals, a debugger, tests, ROS 2 inspection and source control.
Hardware
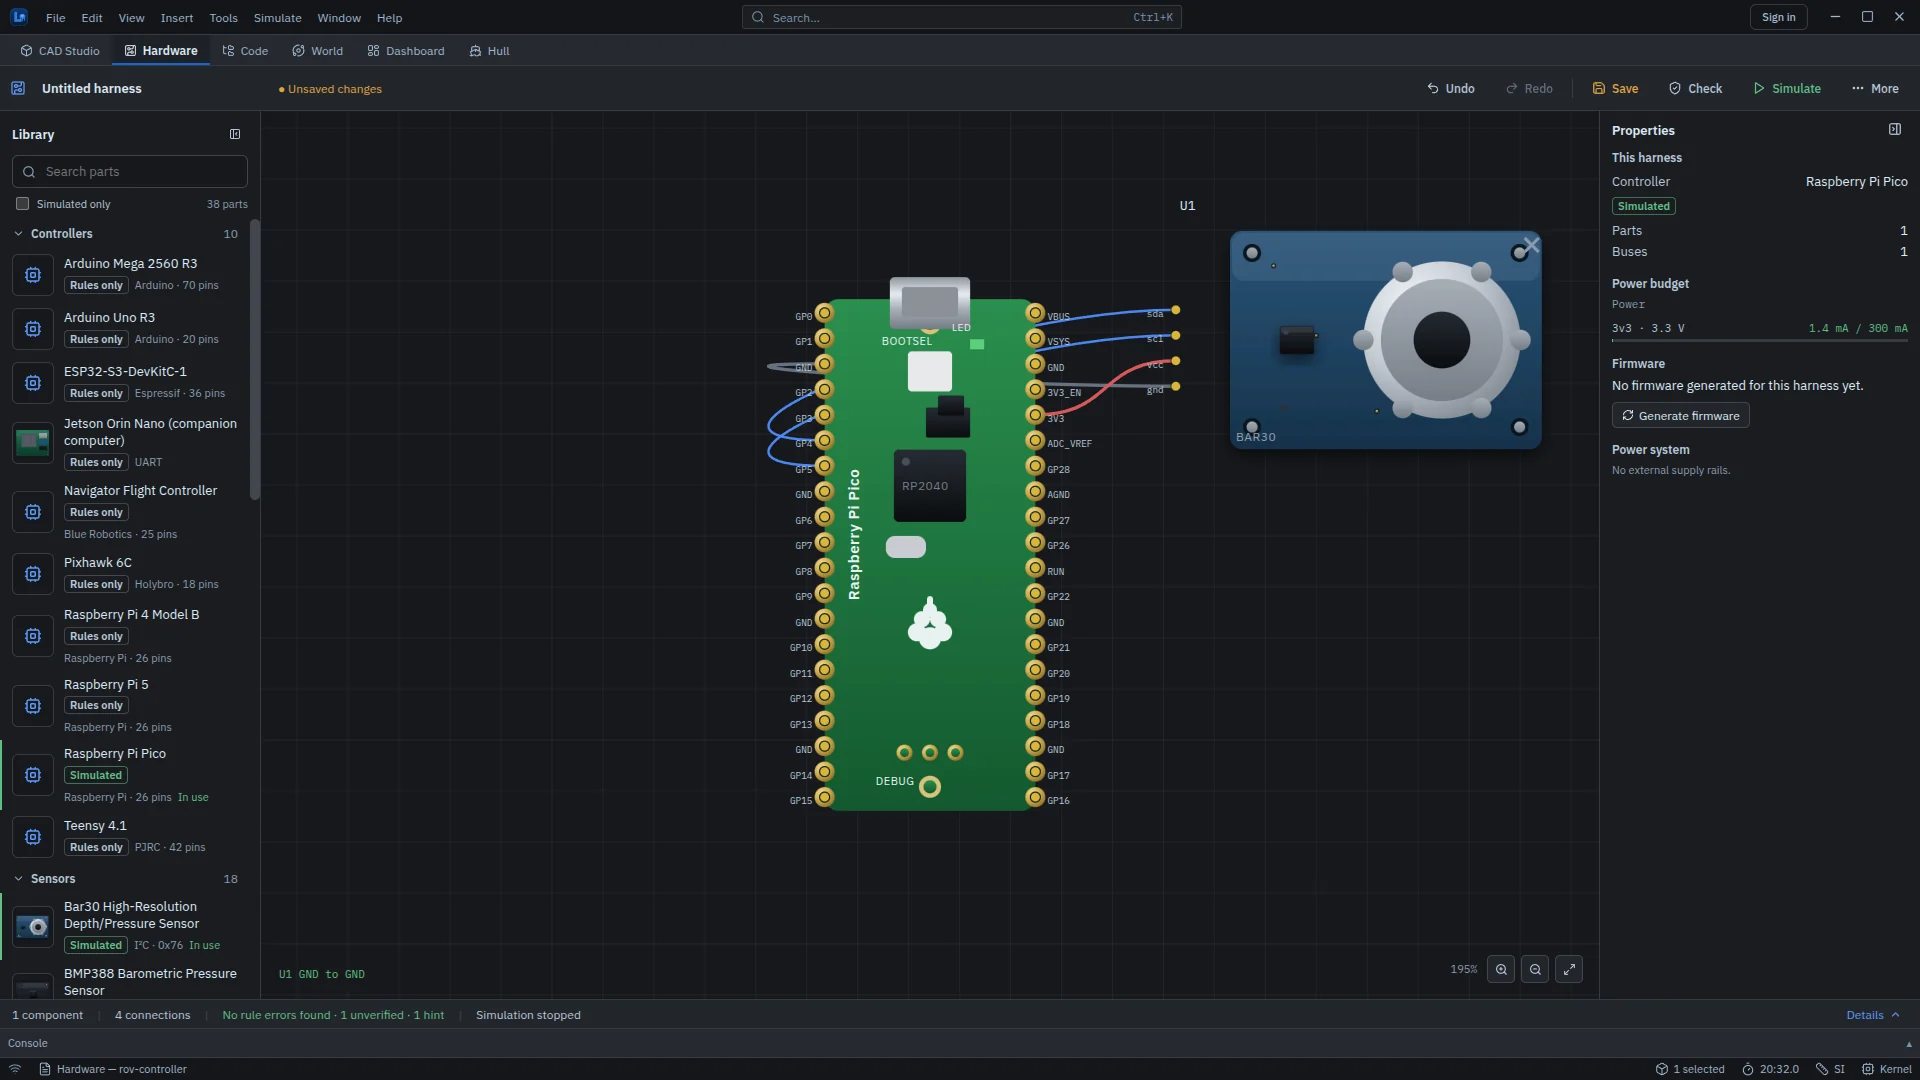
An electronics workbench: pick a controller, add sensors and actuators from a library of 38 parts, wire them, and check the harness against pin, bus, address, voltage, current and power rules. Generate a firmware project, and run the compiled firmware against simulated sensors.
World
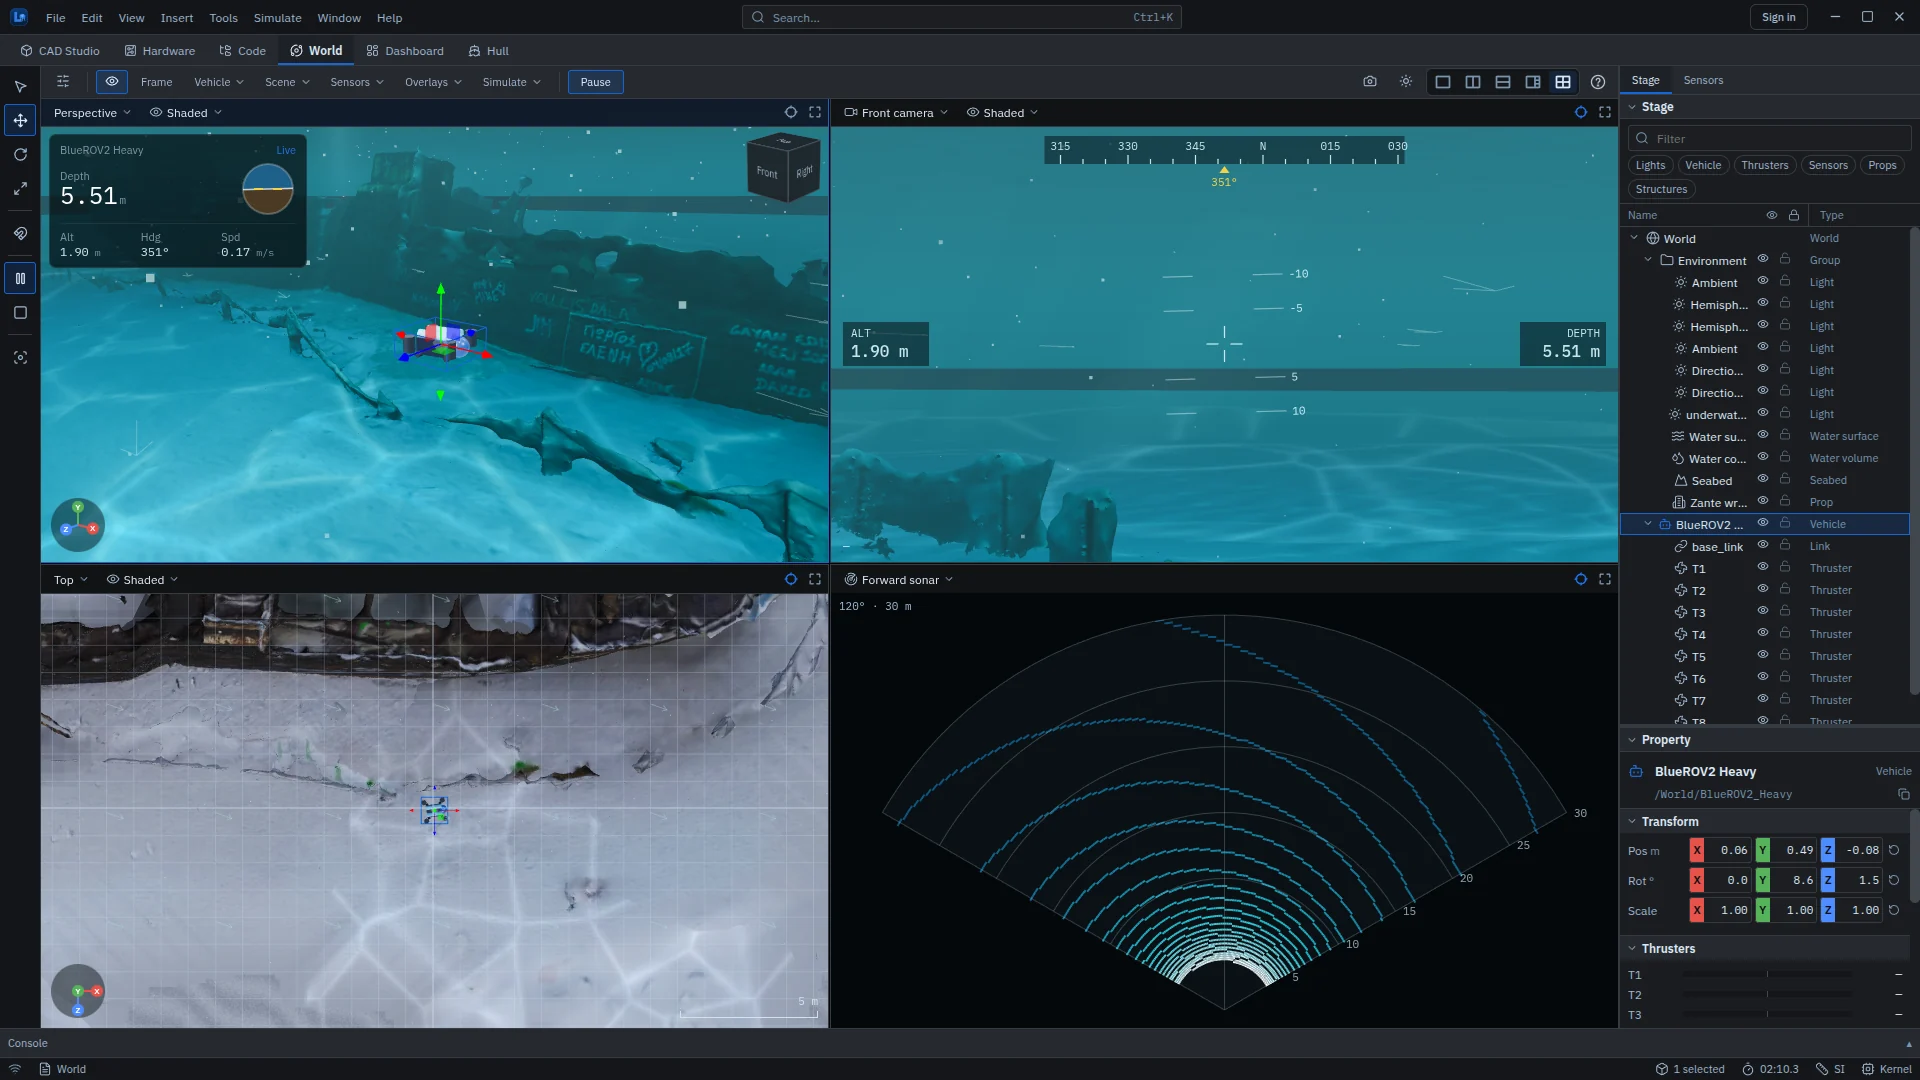
The 3D simulation: a vehicle in one of nine scenes, thirteen sensors, ten overlays, look-through cameras and sonar, up to four views, and the scene tree with editable properties.
Hull
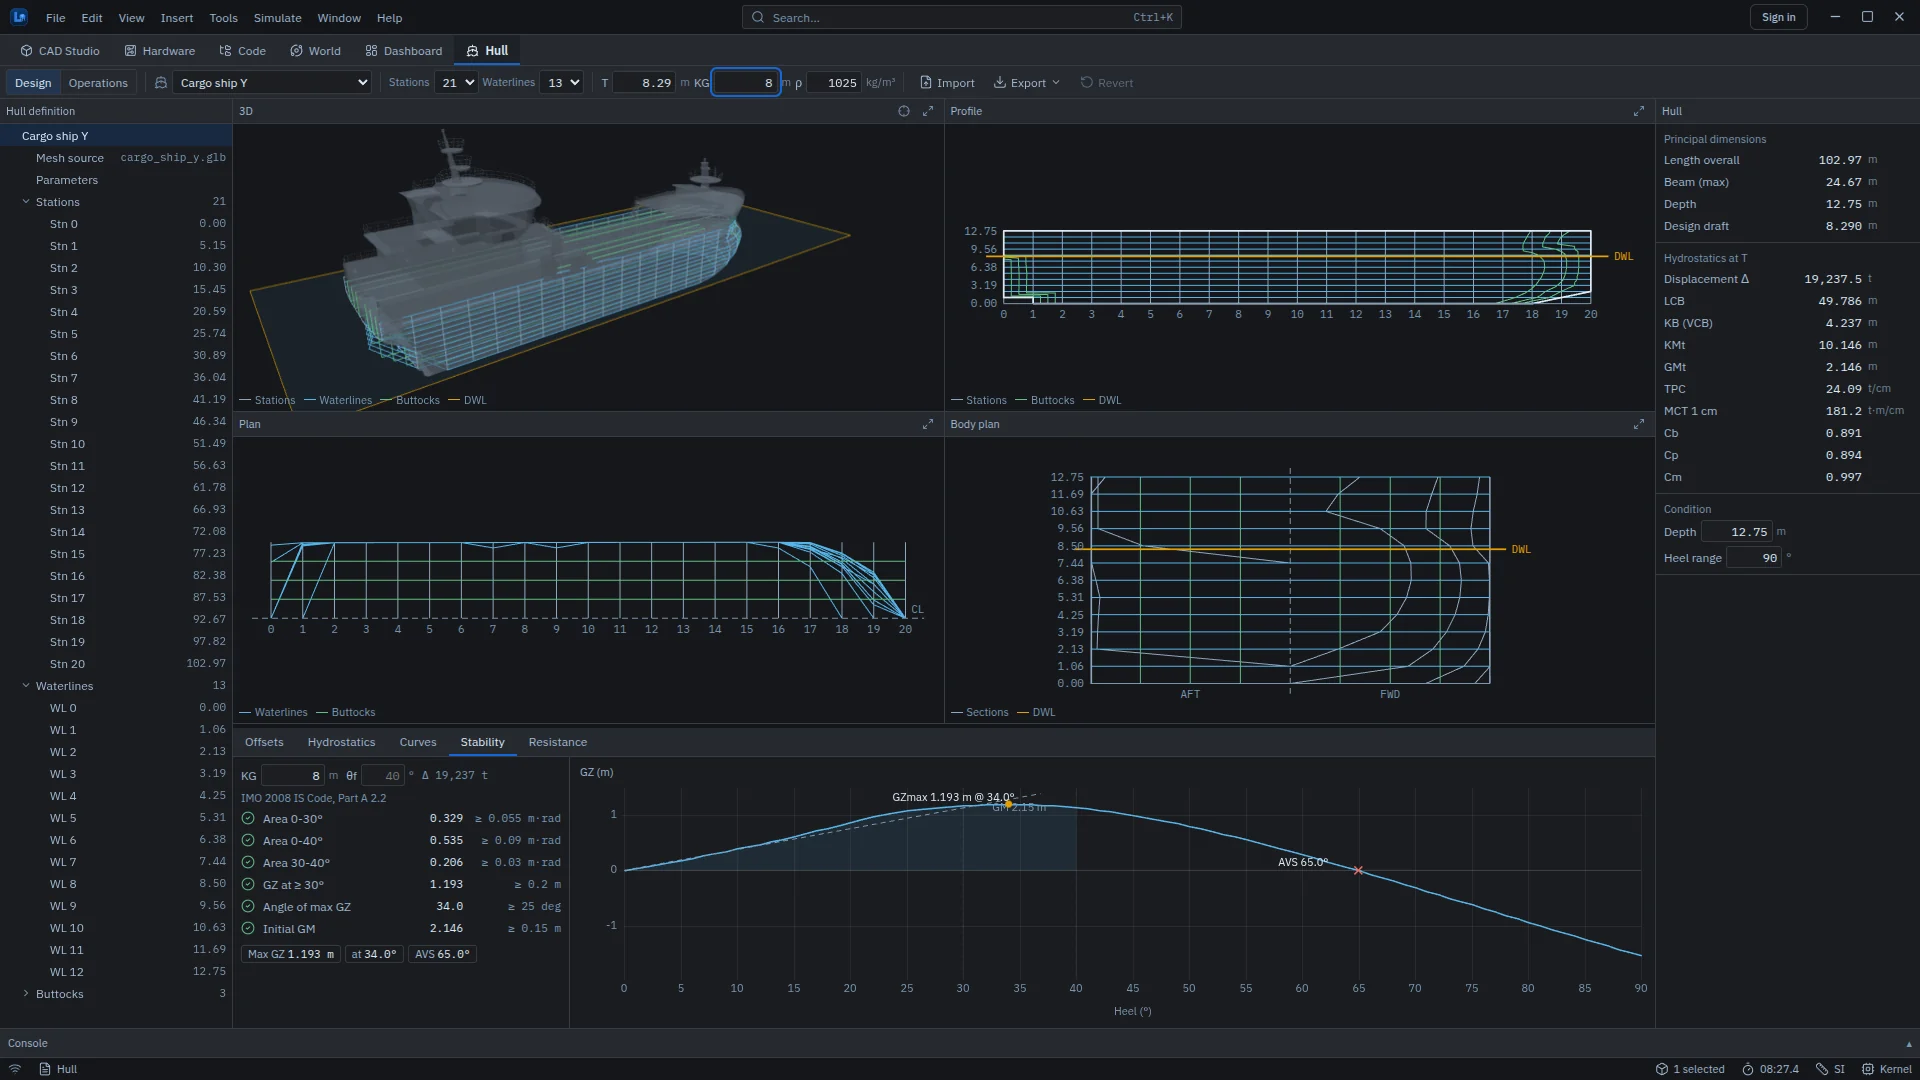
Design mode: lines plan, editable offsets, hydrostatics, curves of form, GZ stability against the IMO 2008 Intact Stability Code criteria, and friction resistance. Operations mode: how fouling grows along a trading pattern, what it costs in power, fuel and carbon, and how a fleet of hull-cleaning robots would clean and inspect the hull.
Dashboard
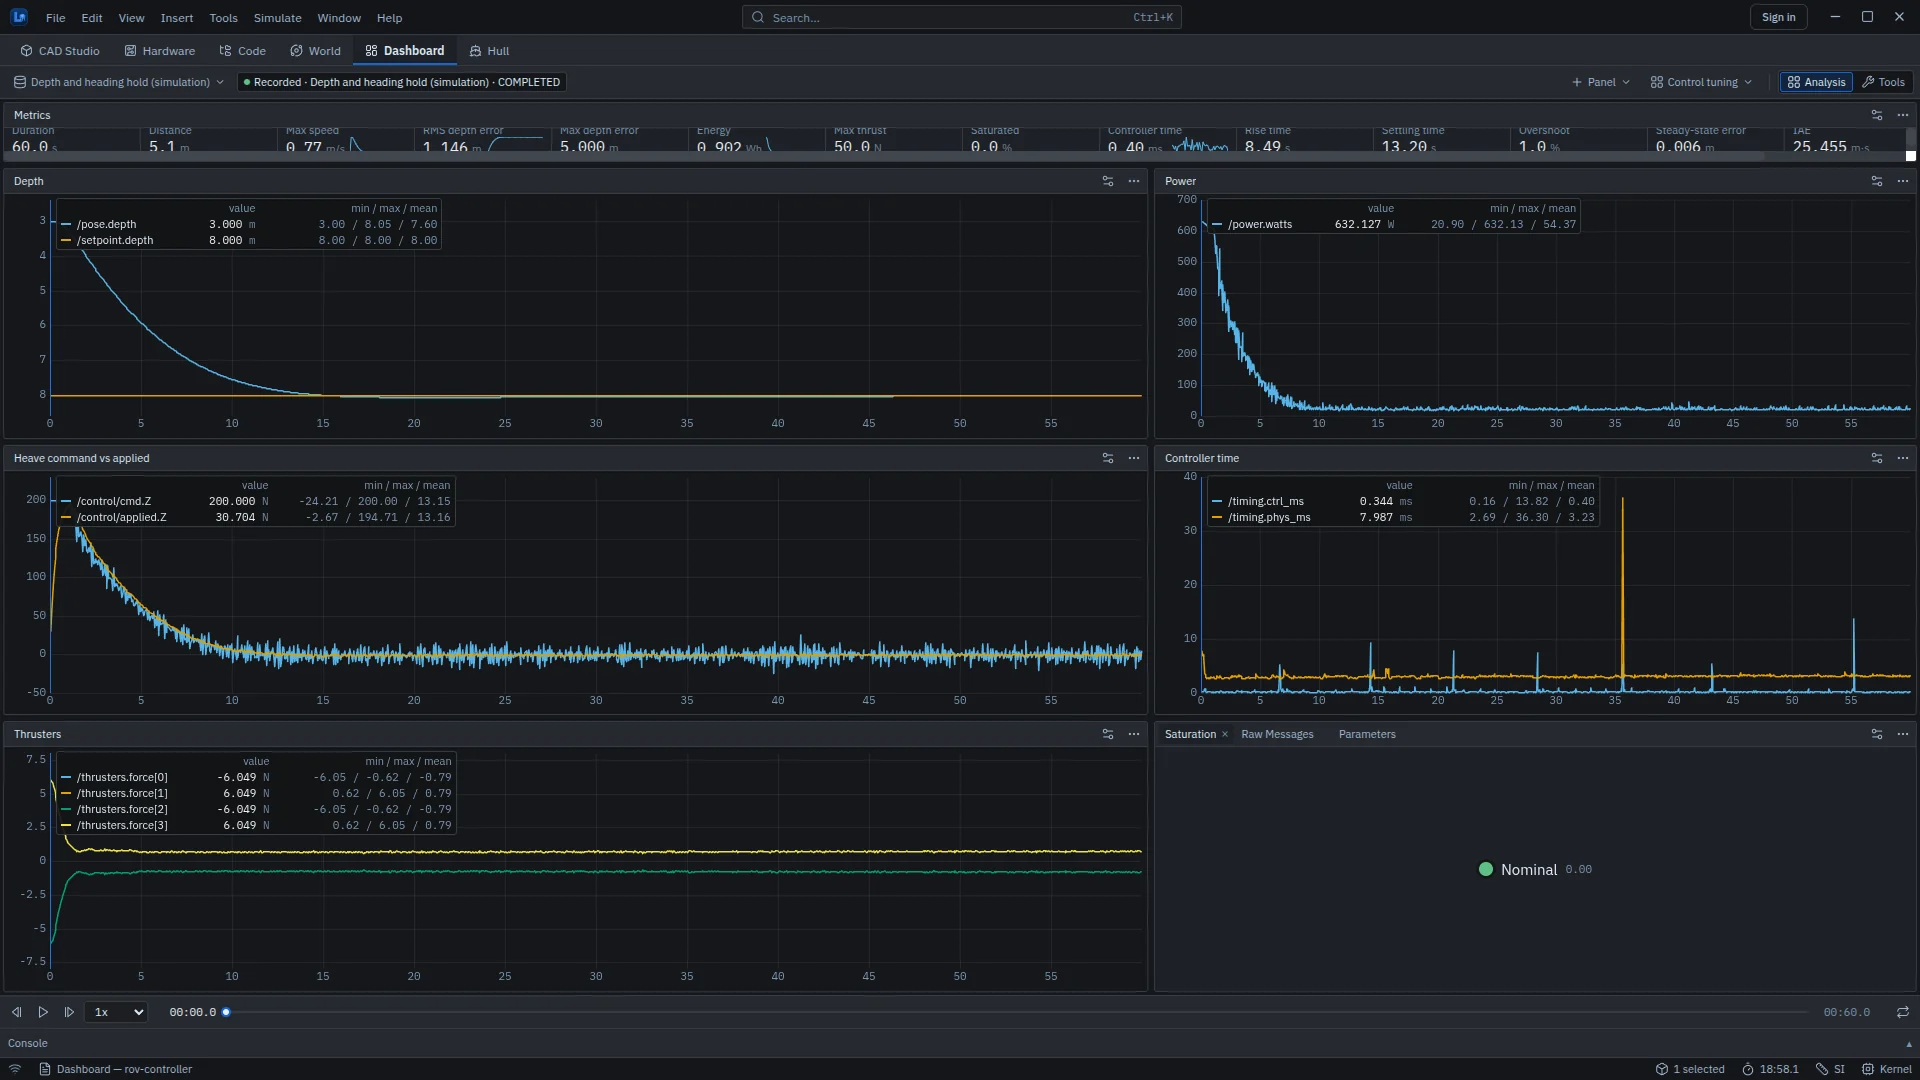
Analysis: a dockable grid of plots, tables, gauges, maps and metrics on a shared timeline, fed by the World, an autopilot simulation link, controller-simulation runs or an imported log. Tools: the catalogue of 85 panels for sensors, physics, charts, estimation, evaluation and interfaces.
Projects and data
A project is a folder; LEVIATHAN keeps its own data for it under ~/.leviathan. Projects are listed in the welcome page and the File menu, and a missing or moved folder is shown as such rather than silently recreated.
| Data | Location | Scope |
|---|---|---|
| Project registry | ~/.leviathan/projects/ | all projects |
| Project settings, run configurations | <project>/.leviathan/ | per project |
| CAD documents | ~/.leviathan/les/documents/ | shared |
| Hardware harnesses, firmware | ~/.leviathan/harnesses/, firmware/ | shared |
| World assets | ~/.leviathan/world_assets/ | per project |
| Simulation runs | ~/.leviathan/runs/ | shared |
| Dashboard and World view layouts | application storage | per project |