AZAREL ROBOTICSTECHNICAL DOCUMENTATION
LEVIATHAN Documentation
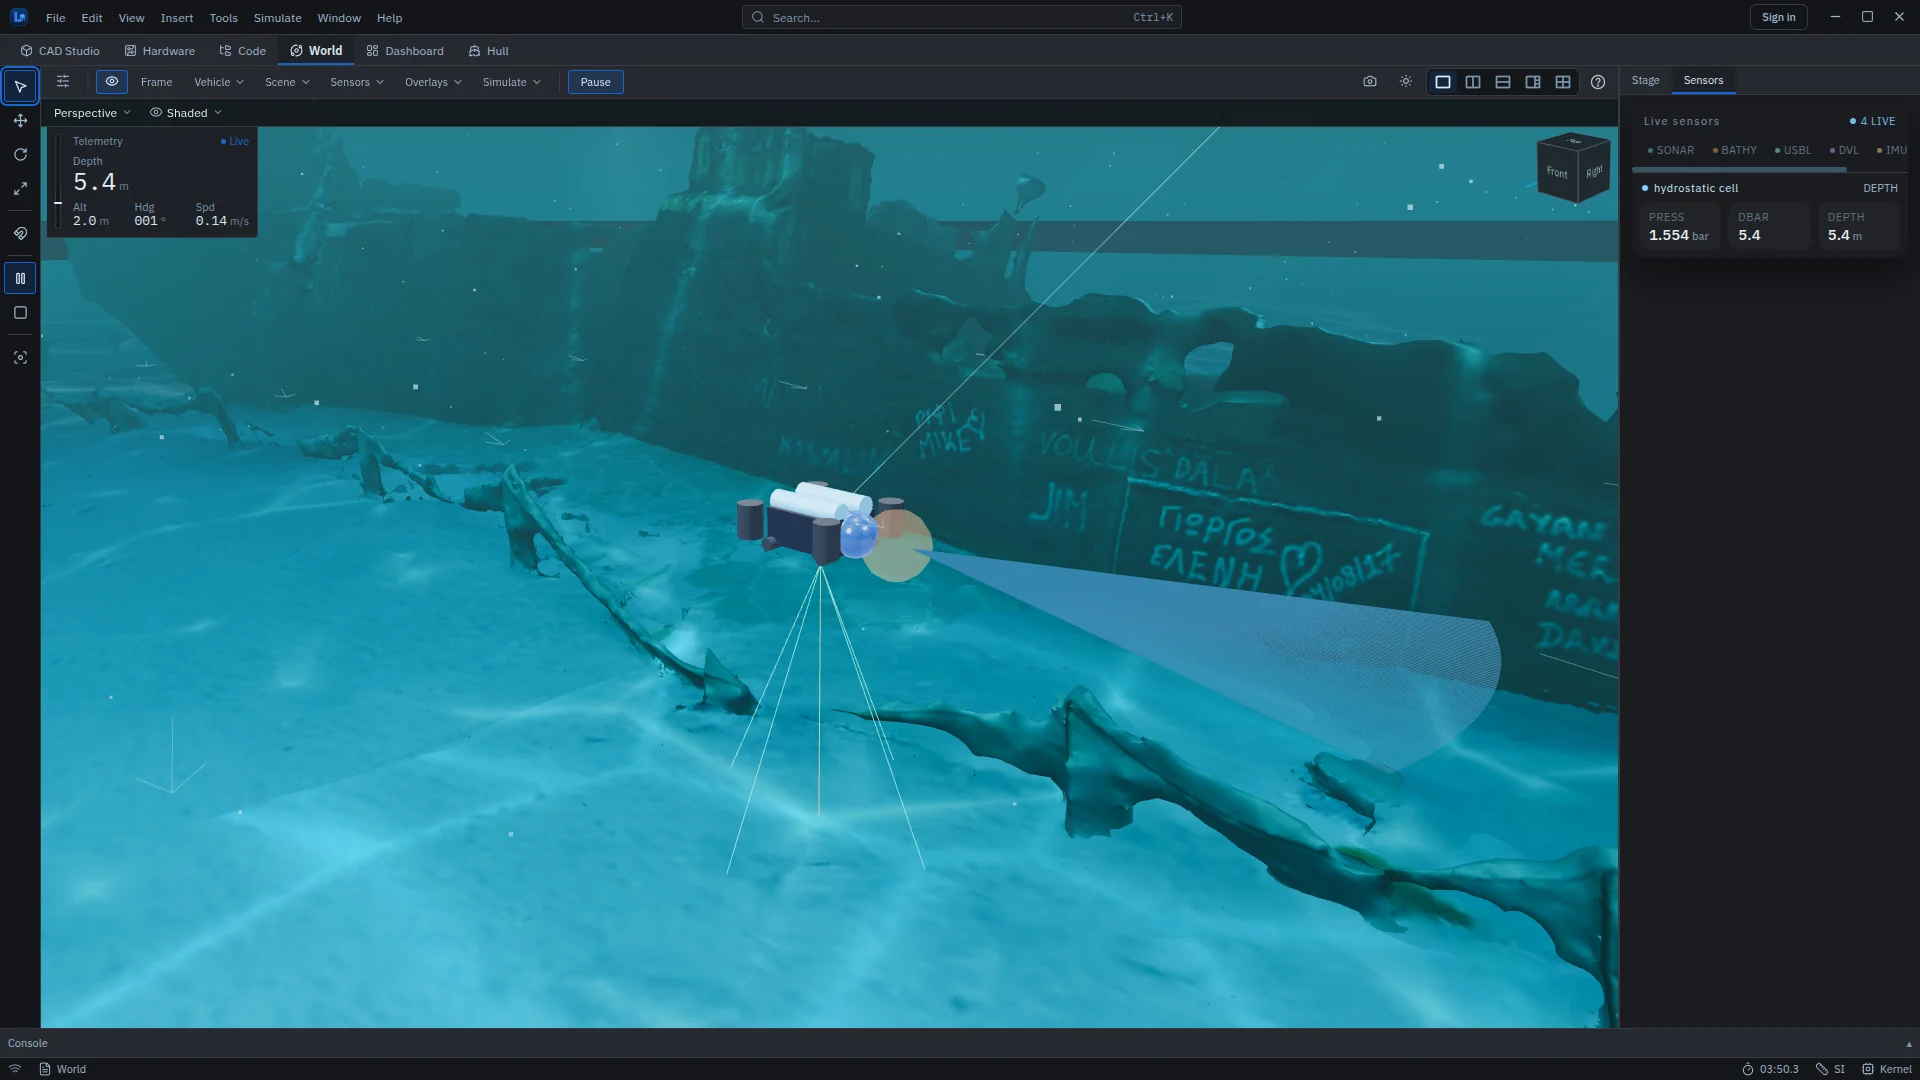
LEVIATHAN is a marine robotics simulation and development environment for AUVs, ROVs, surface vessels and hull robots. It puts vehicles, a modelled ocean, acoustic and optical sensors, ground truth, perception, state estimation, learning and evaluation in one desktop application, backed by a simulation service you can also drive directly.
Vehicles and scenes
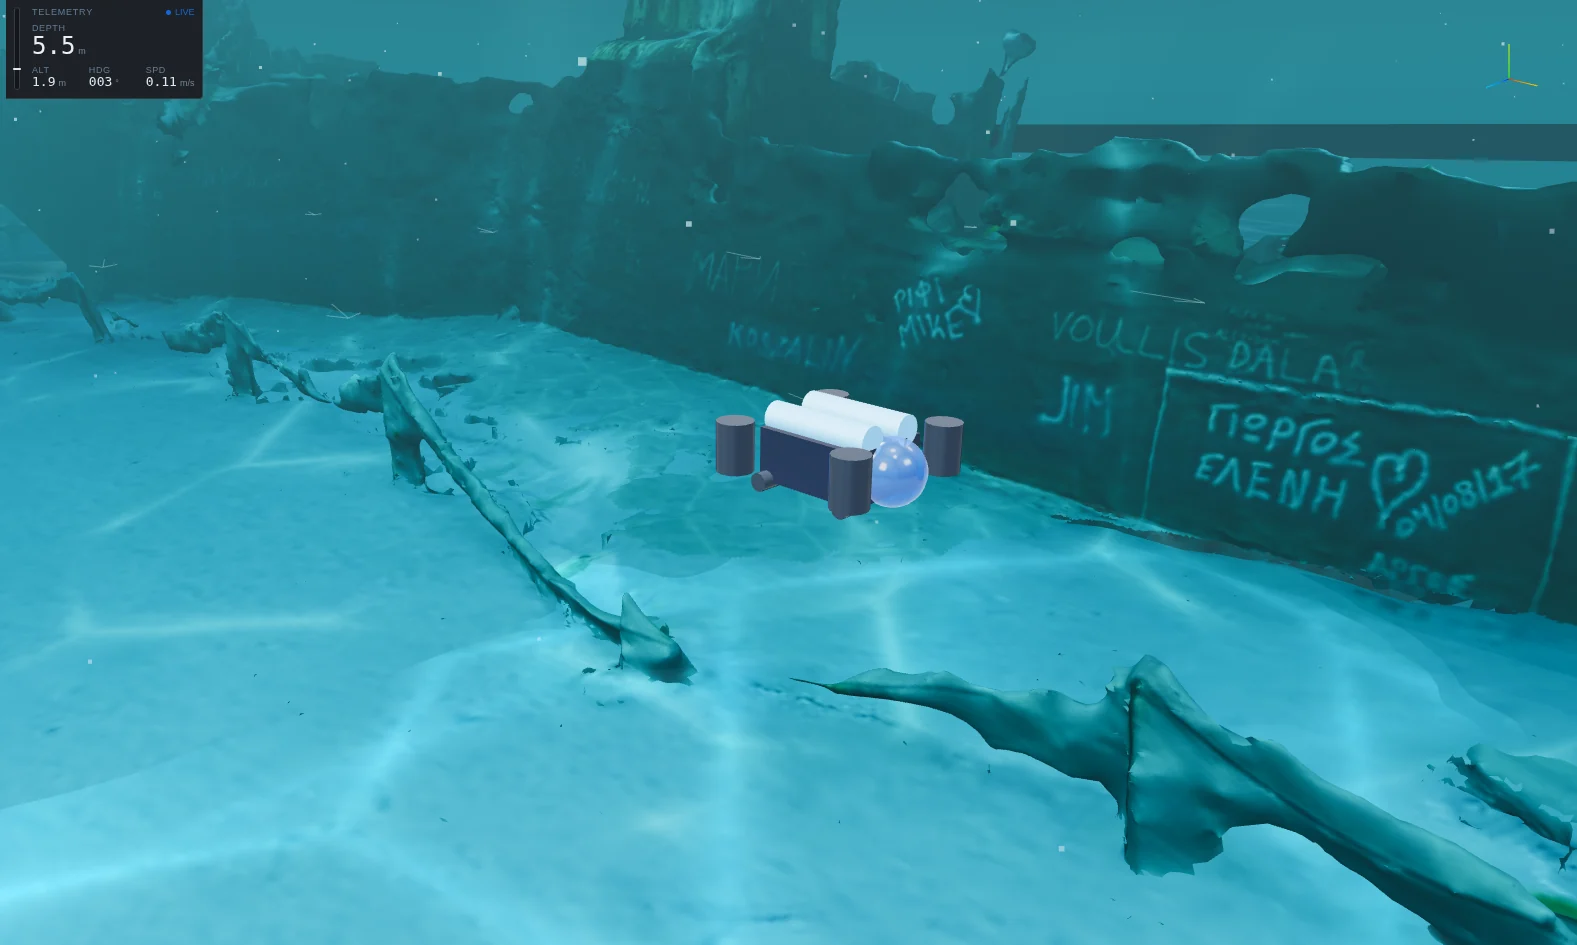
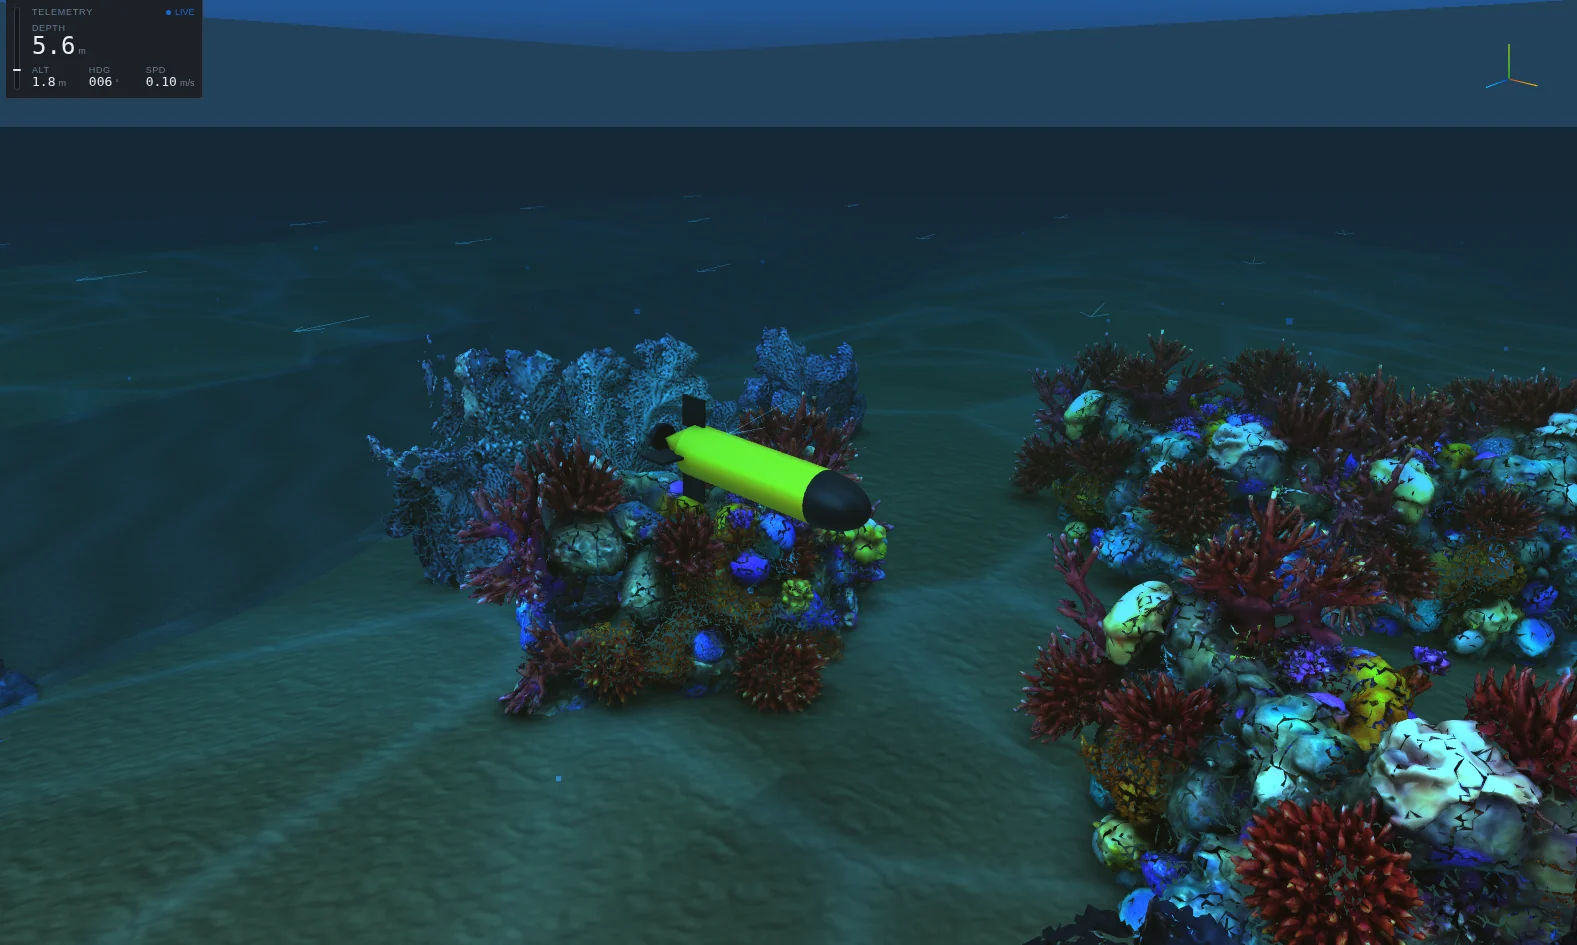
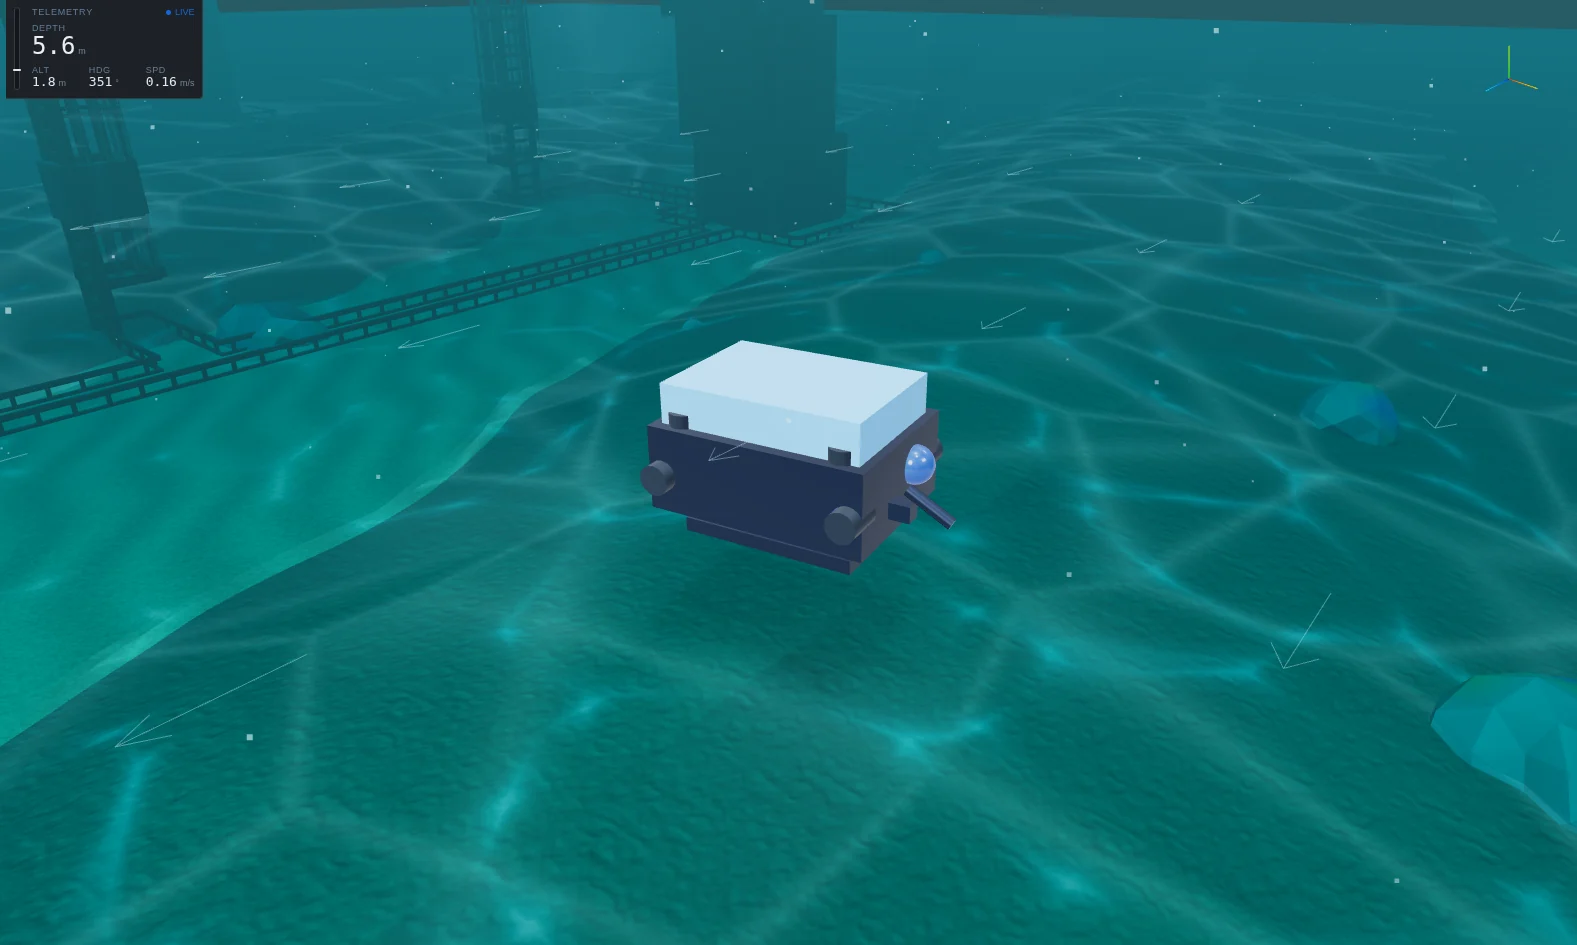
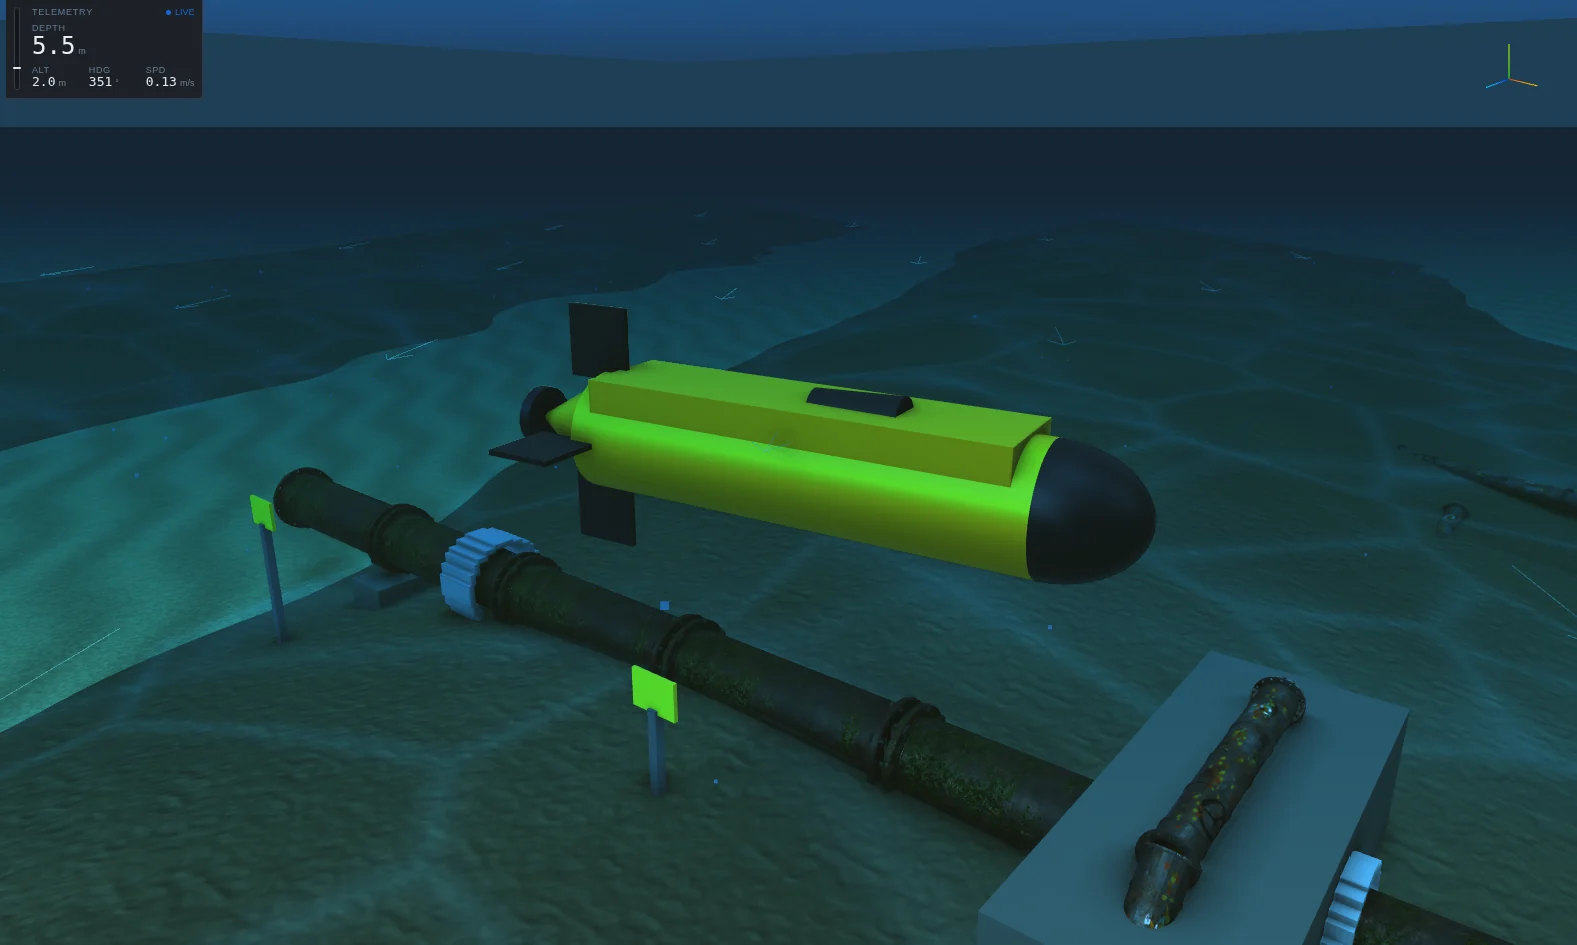
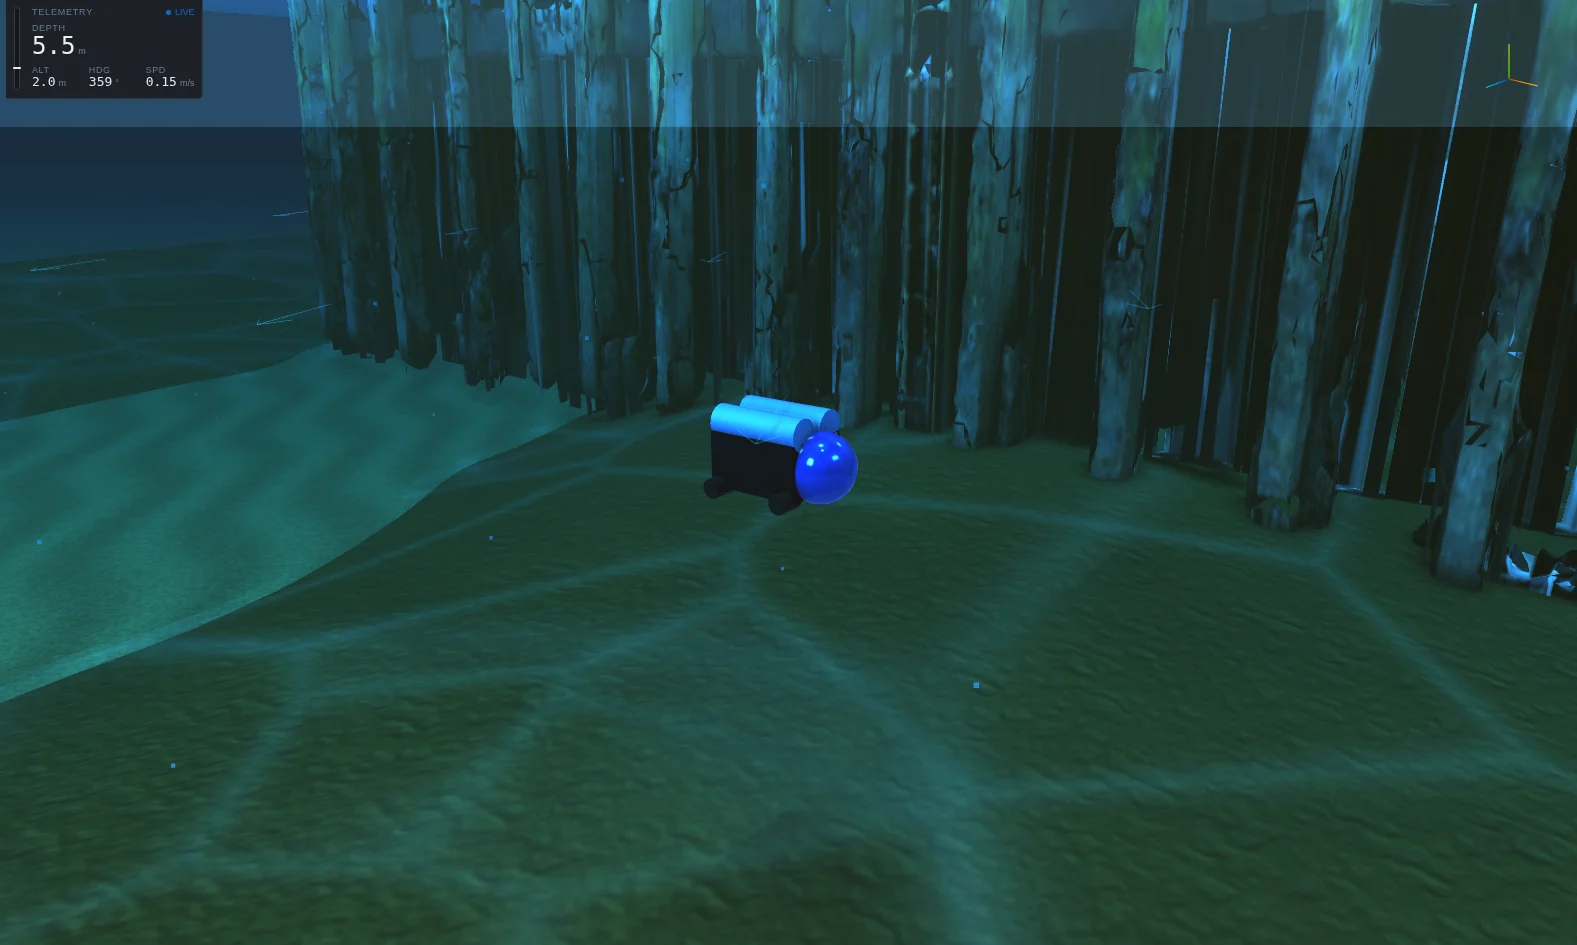
Every screenshot in this documentation is a capture of the running application. Each scene below is a built-in World preset with a built-in vehicle placed in it.
Start here
Workspaces
Simulation
Perception and data
Autonomy and reference
These pages describe what the current release, LEVIATHAN 0.8.0, does. Where a model has known limits, or where a capability is an interface rather than a live integration, the relevant page says so. Numbers shown for built-in vehicles are LEVIATHAN simulation presets.